I take robots from concept to contact — high-density PCBs and real-time
firmware, perception and SLAM, simulation and precision control — and prove them on
real hardware, from surgical manipulators to Boston Dynamics SPOT.
One question defines my work. It pulls me toward systems that demand extreme precision
and extreme delicacy at the same time — where the machine has to meet the body on its own terms.
The Machine
Precision, modeled and proven
Sub-millimeter motion, observable and controllable. Non-linear dynamics, state-feedback control, and sensor fusion validated before a single part is printed.
Sub-mm precision
State feedback
Sensor fusion
Kinematics
Observers
The Body
Touch, tissue, and healing
Soft, adaptive structures and haptic feedback that let a robot interact with living tissue — giving surgeons a sense of touch and a steadier, gentler hand.
Haptics
Soft / origami
Bio-compatible
Tendon-driven
Recovery
Mission Log · A Robotics Journey
From a single PCB to surgical precision.
Five chapters — from a first production PCB, through research labs and a startup, to surgical-robotics research at Northeastern.
01
2022 · Maskottchen Technologies — Embedded Systems Intern
Respecting the hardware · First production-grade PCB
My start: production embedded systems. I designed motor-driver and mixed-signal PCBs in Altium and Eagle — H-bridges, gate drivers, OCP/SCP power distribution — and shipped firmware across ESP32, STM32, and Raspberry Pi with MQTT pipelines into the cloud. This is where I learned a breadboard is not a product.
At IIT Bombay's Aerial Robotics Lab I refined drone dynamics and implemented A*/RRT navigation in cluttered warehouses — earning a research reward. In parallel, a SLAM fellowship pushed adaptive Canny edge detection for low-light localization, which became my first IEEE paper and a 30% accuracy gain.
Edge accuracy +30%IIT Bombay Research RewardA* · RRT · SLAM · OpenCV
I co-founded a smart-insole company around interchangeable health and acupuncture soles, raised ₹/$ seed funding from the Government of India, and drove the design through real user iterations — better durability, comfort, and cost. The TRISOLE energy-harvesting concept is filed as a patent.
2024 – 2026 · Northeastern University — MS Robotics
Real robots, real cities · SLAM on SPOT & gaze sensing
Boston threw me into autonomous research: Point-LIO SLAM with Velodyne + IMU + GPS fusion deployed on the NUANCE self-driving car and Boston Dynamics SPOT. In the AR/VR Lab I designed a capacitive eye-tracking front-end in Altium and wrote deterministic Teensy firmware — cutting device power by 80%.
Nav robustness +30%Device power −80%Point-LIO · EKF · MCL · Altium
05
CURRENT · Surgical Robotics Research NOW
Where the machine meets the body · Rolling-contact joints & surgical IK
My core research: rolling-contact joints with Kevlar-49 tendons that crush conventional revolute architectures, controlled by pole placement and a Luenberger observer. Alongside it: joint-space virtual fixtures for surgical robots, merged contributions to Enactic's OpenArm, SE(3) inverse kinematics with a gaze constraint in MuJoCo, and Quest-2 → Unitree G1 teleoperation — building toward foundation-model and VLA-driven manipulation.
Hardware to perception to control — every project carried from a question to a number.
Flagship · Surgical RoboticsP / 01
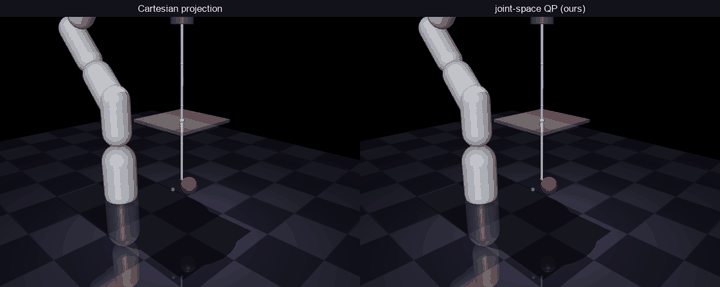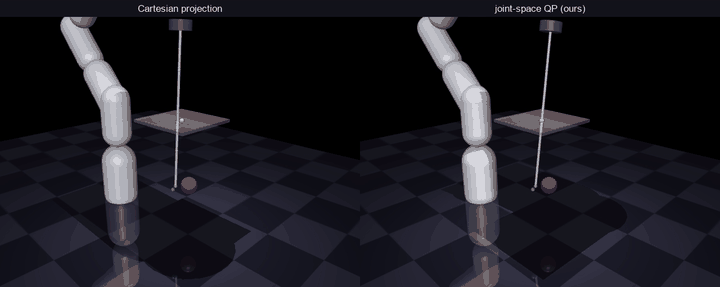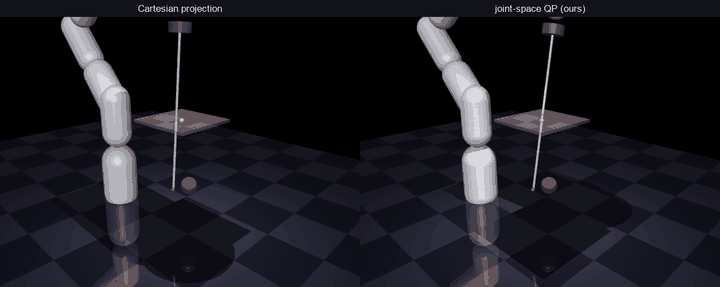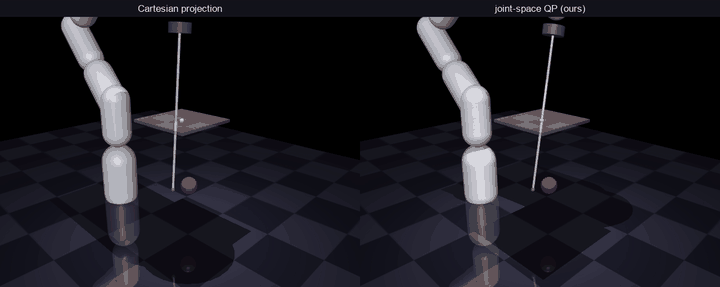
ActiveGuide: Surgical Virtual Fixtures in Joint Space
Safety walls and guidance paths for surgical robots, enforced as hard constraints in one quadratic program per control step, on a Franka Panda and a simulated dVRK PSM in MuJoCo. Holding the trocar in joint space keeps it to 0.50 mm, where a fixture on the tool tip alone levers the shaft 27 mm out of the port. Walls baked from a synthetic organ mesh keep the tool out of the organ, where a sphere approximation lets it 0.68 mm in. 135 tests run in CI, and every number in its README comes from committed demo output.
Trocar 0.50 mm vs 27.35 mmPath error 135×↓PSM remote centre 0.013 mm
Same task and fixtures: Cartesian projection (left) vs. the joint-space QP (right).
Open Source · Enactic OpenArmP / 02
Merged Contributions to Enactic's OpenArm
Fixes to the ROS 2 stack of OpenArm, Enactic's open-source humanoid arm: a can_fd launch argument through bringup and MoveIt, a fix for OpenArm 2.0 silently ignoring its CAN-interface launch arguments, a fix that brings back namespaced controllers (arm_prefix), a bringup README brought up to date, and an unmaintained Docker setup removed, each tested with real ROS 2 Jazzy launches.
Four deep-RL algorithms on a four-phase tissue-retraction task, five seeds each. Hierarchical skill chaining (ViSkill) finished at 64% success against 11–30% for SAC, DDPG and DEX, and over the last 50k steps every ViSkill run beat every baseline run. Re-checking my course paper against the code, I found its sub-policies were not isolated as claimed, fixed it, re-ran all 25 runs, and published an errata that CI checks against the code.
A from-scratch SE(3) Newton-Raphson IK solver driving a 7-DoF Franka Panda in MuJoCo along a circular endoscope trajectory while aiming the camera at a fixed tissue target (a gaze constraint), with null-space redundancy resolution. Tracking is sub-millimetre for ~80% of the lap, then diverges as q1 reaches its joint limit.
Deployed Unitree's open-source teleoperation stack driving a G1 humanoid in MuJoCo at 30 Hz from a $300 consumer headset. I built the enabling layer — WSL2 mirrored networking, the SSL certificates WebXR requires, the C++ MuJoCo build and launch orchestration — and debugged latency and connection recovery stage by stage across the WebXR → WebRTC → IK → DDS → simulator chain. Built as demonstration-data infrastructure for imitation learning.
Surfaces that roll instead of pivot — virtually eliminating sliding friction and wear, with a variable center of rotation that mimics the moving axes of human knee and finger joints. A full non-linear dynamic model (tendon elasticity, friction, backlash) drives a pole-placement controller and a Luenberger observer running 3× faster than the loop. The mechanism at the heart of high-dexterity, sterilizable surgical grippers.
Two perception pipelines for the surgical field: 6-DoF instrument pose tracking on the MICCAI EndoVis benchmark — handling occlusion, specular reflection, and texture-poor surfaces — and a Farneback dense-optical-flow tracker that recovers cardiac cycle and heart rate from monocular endoscopic video. The vision backbone for an autonomous, self-positioning endoscope.
A robust localization stack deployed on two real platforms — the NUANCE self-driving car and Boston Dynamics SPOT. Point-LIO SLAM fuses Velodyne LiDAR with vision; an EKF blends IMU and GPS for drift-free trajectories; Monte-Carlo Localization holds up where features run thin. Full sensor calibration: camera-LiDAR extrinsics, IMU bias, magnetometer hard/soft-iron correction.
Nav robustness +30%Yaw accuracy +25%Loop closure +20%
A linearized continuous-time model with full controllability and observability, driven by pole-placement state feedback and a Luenberger observer — visualized through a MATLAB GUI that compares joint architectures in real time under tissue-contact disturbance, with Kevlar-49 vs Nylon-66 material analysis.
Peak torque −73%Tracking error −64%Settle <0.5s
Pole placementLuenberger observerMATLABMaterial analysis
Research in Northeastern's AR/VR Lab: a mixed-signal Altium PCB for capacitive eye-tracking — transimpedance front-end, differential measurement, separated analog/digital grounds — paired with interrupt-driven C++ firmware on a Teensy (Cortex-M7) hitting a sub-millisecond deterministic control loop. Validated across 100+ HIL regression cycles.
Two live toys, built from my actual research. Drag them, break them, watch the algorithms fight back.
Probabilistic Robotics
Monte-Carlo Localization
A particle filter estimating a robot's pose from noisy range beacons — the localization core I ran on Boston Dynamics SPOT. Drag to drive the robot and watch the cloud collapse onto the truth. Hit Kidnap to teleport it and watch the filter recover.
Particles —Est. error —converging…
↳ drag on the map to drive
Mechanism Design
Rolling-Contact vs Revolute
My research, made tactile. Flex the joint and compare a sliding revolute pivot against a rolling-contact joint — watch the contact sliding (the source of friction & wear) and the instantaneous center of rotation diverge.
Flex 0°Revolute slip 0.0RCJ slip 0.0
Pure vanilla canvas — no engine, no dependencies. The same instinct I bring to embedded firmware: make it run anywhere, fast.
Research & Recognition
Published, cited, and patented.
Seven peer-reviewed papers (4 IEEE, 2 IET, 1 AIP), three filed patents, and open-source code — research that leaves the lab.
MS Robotics, Northeastern University (April 2026) — open to surgical, humanoid, and
autonomous robotics roles. STEM OPT authorized through May 2029, available globally.
If you're building precision systems that meet the body, let's talk.